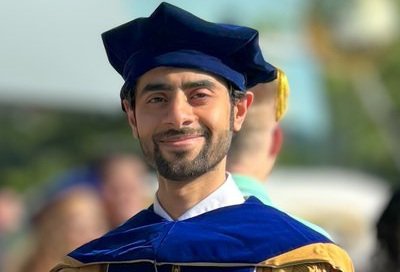
Dr Hassan Almubarak
Assistant Professor
Research Scholar, Interdisciplinary Research Center for Smart Mobility & Logistics
🏢22-321-1
✆+966-13-860-5442
Research Group: Autonomous Control, Optimization and Robotics (CORTx) Lab
Education:
- PhD, Electrical and Computer Engineering, Georgia Institute of Technology, USA, 2024
- MSc, Electrical and Computer Engineering, Georgia Institute of Technology, USA, 2018
- BSc, Control Systems Engineering, KFUPM, Saudi Arabia, 2016
Teaching:
- CIE 305 Linear Control Systems
- EE 380 Control Engineering I
- SCE 507 Linear Multivariable Control
Research Interests:
- Enterprise AI Solutions.
- Safety-critical Control.
- Robotics and Autonomous Systems.
- Optimal and Learning Control.
- Machine Learning.
- Controls for AI and ML.
- Data-driven Control and Model-based Reinforcement Learning.
- Large-Scale Dynamic Optimization.
- Muli-agent Optimization and Control.
- Adaptive Model Predictive Control.
- Intelligent Systems Optimization.
Current Students
- Mohammed K. Al-Ghaili (MS Student)
- Yakoop R. Qasim (MS Student)
- Sharfiden H. Yusuf (PhD Student)
- Ibrahim Ibrahim (PhD Student)
- Sadiq Shuaibu (PhD Student)
- Ali Alnasser (part-time PhD Student)
- Karim Mahmoud (PhD Student)
- Fabiha Raheel (PhD Student)
Publications:
Journal Publications
- H. Almubarak, N. Sadegh, and E. A. Theodorou, “Barrier States Theory for Safety-Critical Multi-Objective Control,” IEEE Transactions on Automatic Control, 2025, doi: 10.1109/TAC.2025.3584908.
- H. Almubarak, K. Stachowicz, N. Sadegh, and E. A. Theodorou, “Safety Embedded Differential Dynamic Programming Using Discrete Barrier States,” IEEE Robotics and Automation Letters, vol. 7, no. 2, pp. 2755–2762, 2022, doi: 10.1109/LRA.2022.3143301.
- H. Almubarak, N. Sadegh, and E. A. Theodorou, “Safety Embedded Control of Nonlinear Systems via Barrier States,” IEEE Control Systems Letters, vol. 6, pp. 1328–1333, 2021, doi: 10.1109/LCSYS.2021.3093255.
Conference Proceedings and Presentations
- M. F. Al-Sunni, H. Almubarak, and J. M. Dolan, “LLA-MPC: Fast Adaptive Control for Autonomous Racing,” in Proc. IEEE/RSJ Int. Conf. Intelligent Robots and Systems (IROS), 2025 (to appear).
- M. F. Al-Sunni, H. Almubarak, and J. M. Dolan, “Safety Embedded Adaptive Control Using Barrier States,” in Proc. American Control Conf. (ACC), 2025.
- A. Oshin, H. Almubarak, and E. A. Theodorou, “Differentiable Robust Model Predictive Control,” in Proc. Robotics: Science and Systems (RSS), 2024.
- J. E. Kuperman, H. Almubarak, A. D. Saravanos, and E. A. Theodorou, “Improved Exploration for Safety-Embedded Differential Dynamic Programming Using Tolerant Barrier States,” in Proc. 21st Int. Conf. Advanced Robotics (ICAR), 2023.
- H. Almubarak, E. A. Theodorou, and N. Sadegh, “Barrier States Embedded Iterative Dynamic Game for Robust and Safe Trajectory Optimization,” in Proc. American Control Conf. (ACC), 2022, pp. 5166–5172.
- H. Almubarak, E. A. Theodorou, and N. Sadegh, “Safety Embedded Differential Dynamic Programming Using Discrete Barrier States,” in Proc. IEEE Int. Conf. Robotics and Automation (ICRA), 2022.
- C. Aoun, P. Zhao, H. Almubarak, N. Hovakimyan, and E. A. Theodorou, “L1 Adaptive Control of Constrained Systems Using Barrier States,” in AIAA SciTech Forum, Guidance, Navigation, and Control Conf., 2023.
- H. Almubarak, E. A. Theodorou, and N. Sadegh, “HJB Based Optimal Safe Control using Control Barrier Functions,” in Proc. 60th IEEE Conf. Decision and Control (CDC), 2021.
- H. Almubarak, E. A. Theodorou, and N. Sadegh, “Safety Embedded Control of Nonlinear Systems via Barrier States,” in Proc. 60th IEEE Conf. Decision and Control (CDC), 2021.
- H. Almubarak, N. Sadegh, and D. G. Taylor, “Infinite Horizon Nonlinear Quadratic Cost Regulator,” in Proc. American Control Conf. (ACC), 2019, pp. 5570–5575.