Thesis/Dissertation Defenses
-
MultiObjective PlantWide Opt. & Control of Tennessee Eastman Process From Mechanistic EMPC to SurrogateAssisted DataDriven RealTime Optimization
-
MS Thesis Defense on "Robust Attitude Control of a 3-DOF Quadcopter: Theory and Experiments"
-
MS Thesis Defense on Intelligent Dispatch & Control Strategies for Microgrids: Integrating Model Predictive Control, Metaheuristic Optimization, & Machine Learning
-
MS Thesis Defense on "Supervisory Energy Management and Control of Grid-Connected Net Zero Energy Buildings Using Co-Simulation"
-
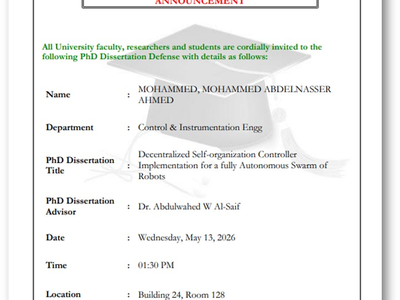
PhD Dissertation on "Decentralized Self-Organization Controller Implementation for a Fully Autonomous Swarm of Robots"
-
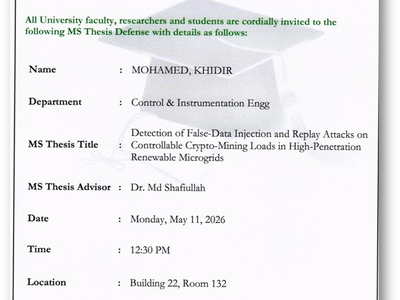
MS Thesis Defense on "Detection of False-Data Injection and Replay Attacks on Controllable Crypto-Mining Loads in High-Penetration Renewable Microgrids"
-
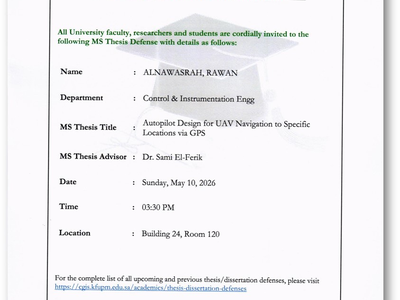
MS Thesis Defense on "System-Level Design, Experimental Validation, and Optimization of a Four-Layer PCB Embedded Autopilot System"
-
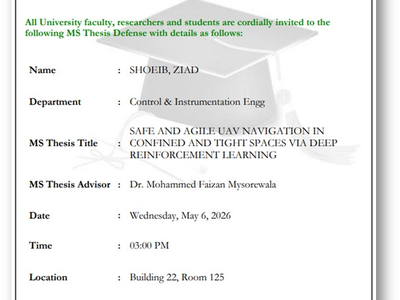
MS Thesis Defense on "Safe and Agile UAV Navigation in Confined and Tight Spaces via Deep Reinforcement Learning"
-
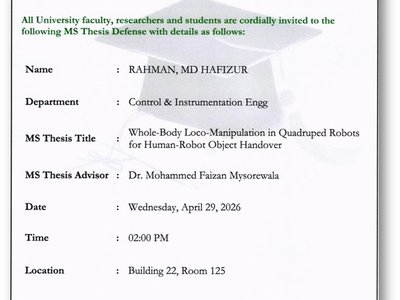
MS Defense on "Whole-Body Loco-Manipulation in Quadruped Robots for Human-Robot Object Handover"
-
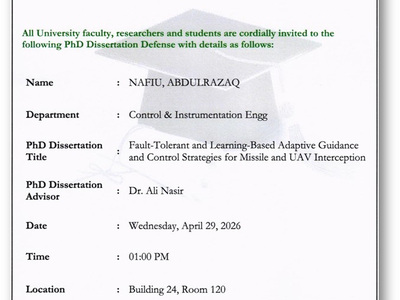
PhD Dissertation Defense on "Fault-Tolerant and Learning-Based Adaptive Guidance and Control Strategies for Missile and UAV Interception"