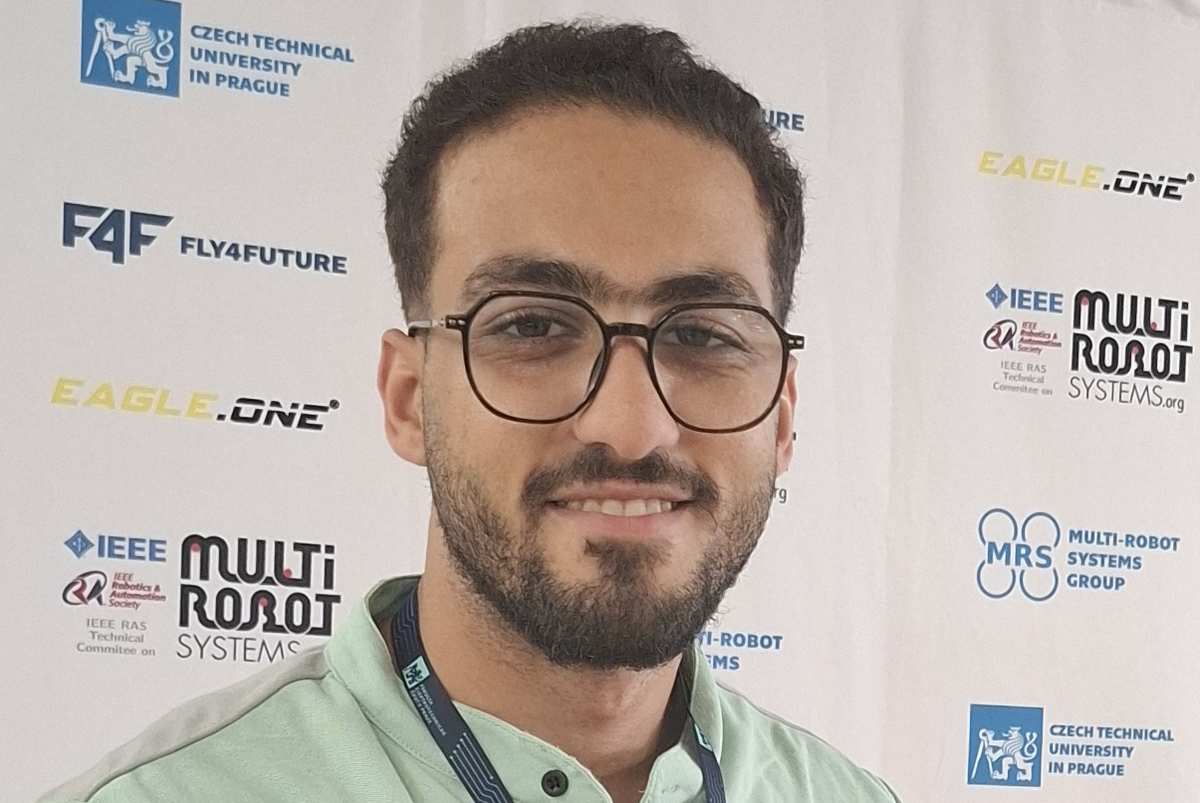
Tarek Eissa
PhD Student
Dissertation Advisor: Dr. Ramy Rashad
Research Areas:
- Robotics,
- Aerial Robotics,
- Aerial Manipulation, and
- Control
Journal / conference publications:
- A Reproducible Simulation Workflow for ISO-Inspired Hybrid Wheeled-Legged Wheelchair Using URDF and PyBullet - ScienceDirect
- [2504.09242] Development of a PPO-Reinforcement Learned Walking Tripedal Soft-Legged Robot using SOFA
- [2503.02673] Implementing PID Controller on a hand follower robot using Numerical Methods
- Model- and Data-Based Control of Self-Balancing Robots: Practical Educational Approach with LabVIEW and Arduino - ScienceDirect
CIE courses/labs assigned:
- In Fall 2025: I taught the Control of Mechatronic system course for Mechatronics department seniors, and also was a lab engineer responsible for the 3d printing operation.
- In Spring 2026: I taught the Path Planning course for Aerospace department seniors, and prepared some ROS demos for help, along with some voluntary work on multiple robotic kits.