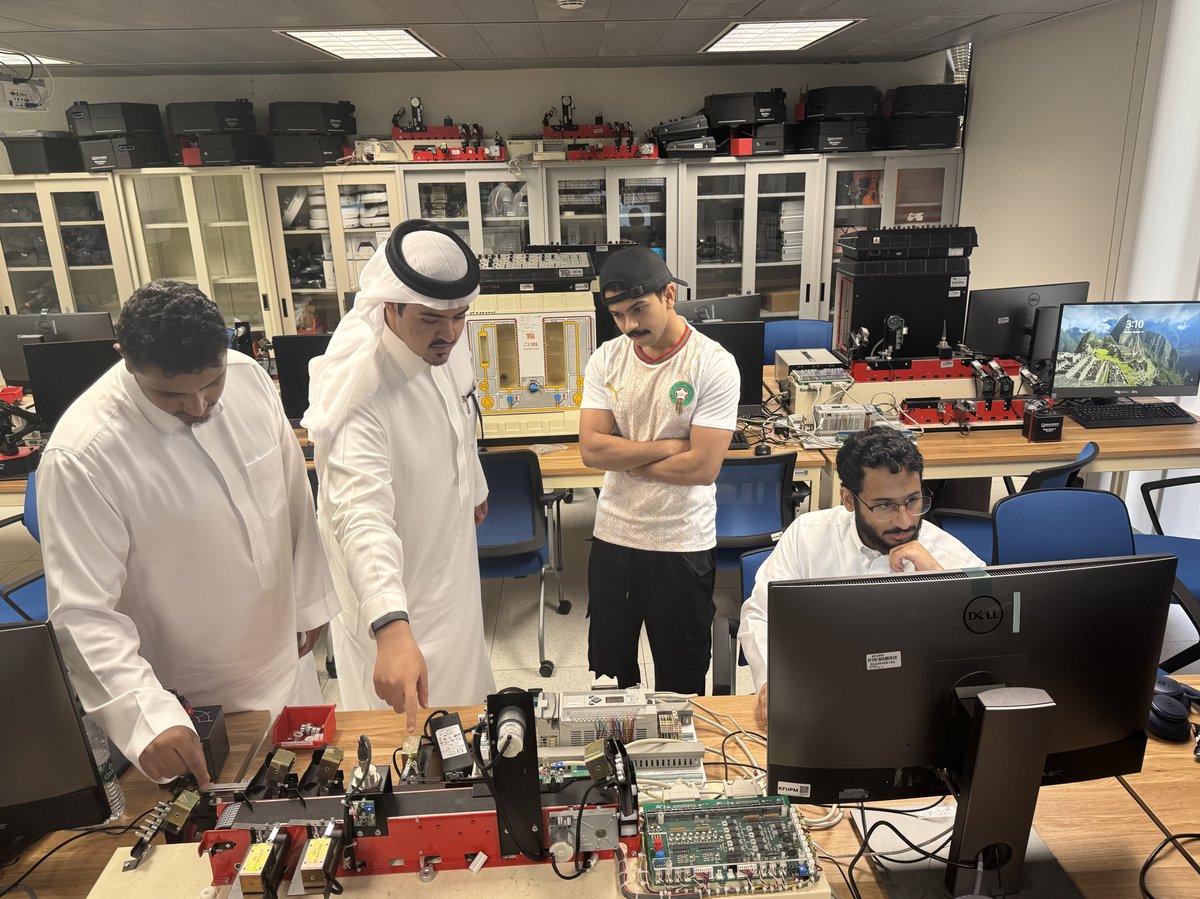
Industrial Automation Lab
Location: B22-236.
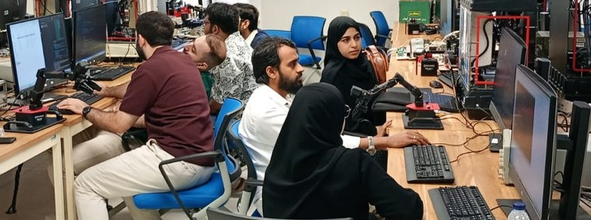
Courses Taught: CIE318 Lab, CIE410 Lab, CX Courses, MX Courses.
Major Apparatus: Coupled Tank Control Systems, Dual Conveyor PLC Trainer Systems, Power Electronic Boards, QBot Ground Robots, Qcar Ground Robots, QArm Mini Robotic Arms, Qube Servo2
Software in use: Matlab, Labview, Quanser Interactive Labs, RSLogix, Factory I/O, Arduino IDE, LogixPro PLC Simulator
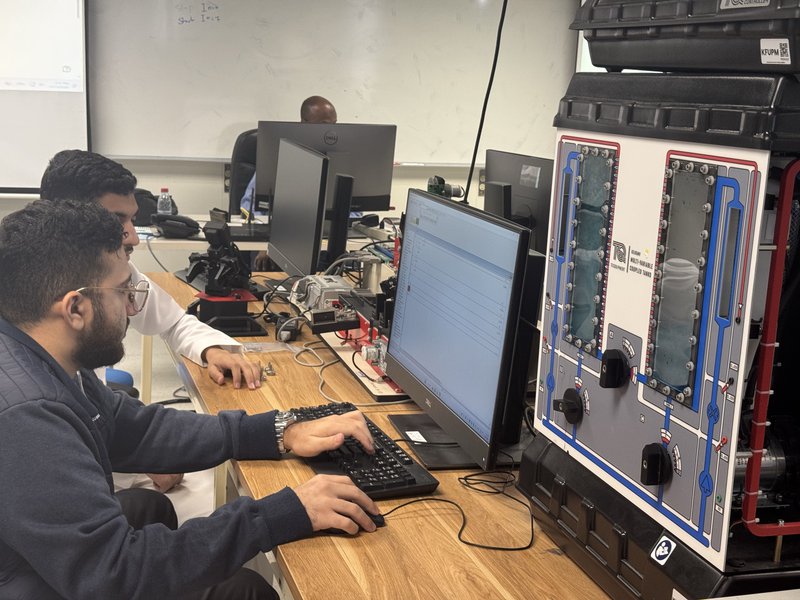
Coupled Tanks Apparatus, a self-contained, bench-mounting apparatus designed to allow students at all academic levels to investigate basic and advanced principles of open and closed-loop control of flowrate and liquid level in single and dual tank systems.
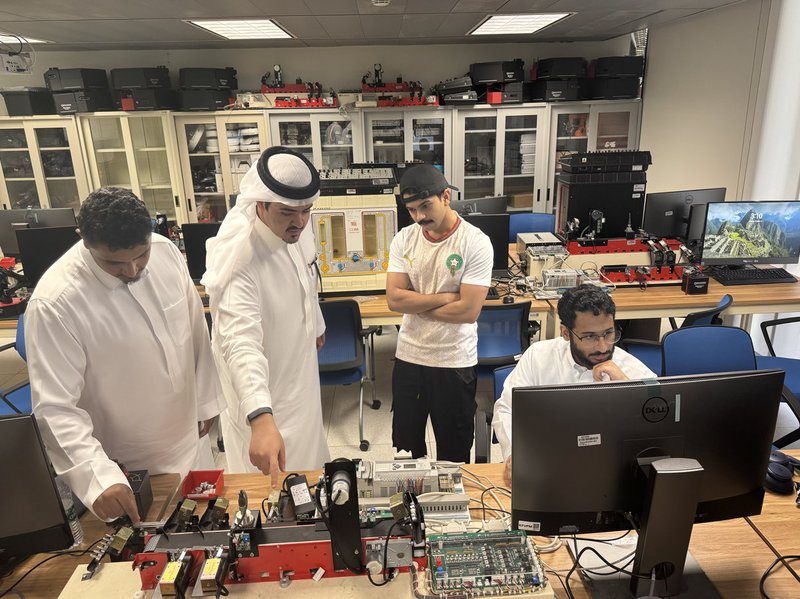
A dual conveyor PLC trainer paired with Allen-Bradley hardware provides a hands-on workcell environment for learning industrial automation, sorting, and material handling.
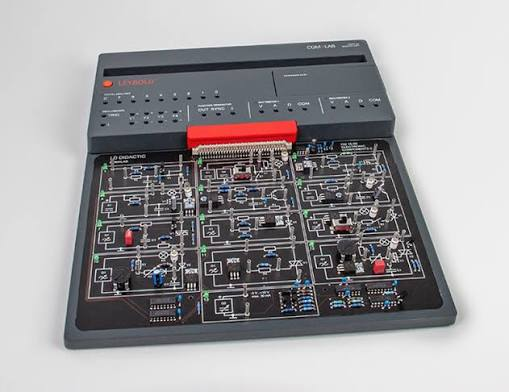
The COM4LAB Power Electronics provides specific courses and hardware modules designed to bridge the gap between semiconductor theory and actual high-power/control applications.
The QArm Mini is a robust and safe arm for teaching introductory manipulator robotics for undergraduate students. Its compact workspace and onboard camera are ideal for practical and engaging learning experiences. Open architecture lab material provides students with a fundamental grasp of robotic manipulator concepts, including position and velocity kinematics, pick and place, object detection and visual-servoing, with support for Python, MATLAB, Simulink, and ROS.
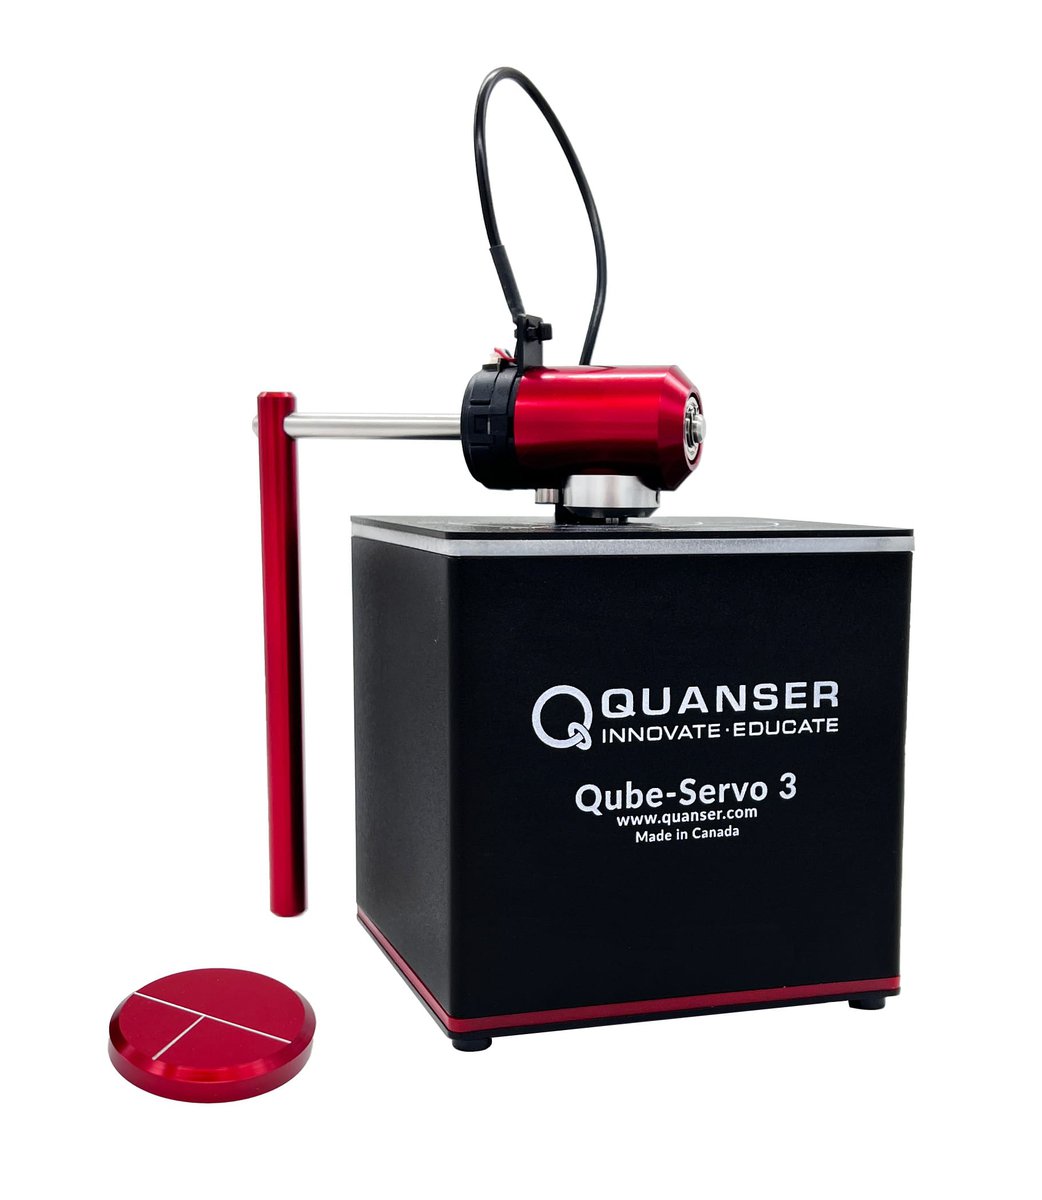
The Qube Servo 3 control system is equipped with a high-quality direct-drive brushed DC motor, two encoders, an internal data acquisition system, and an amplifier. Connect with USB to a Windows PC using MATLAB Simulink or Python.
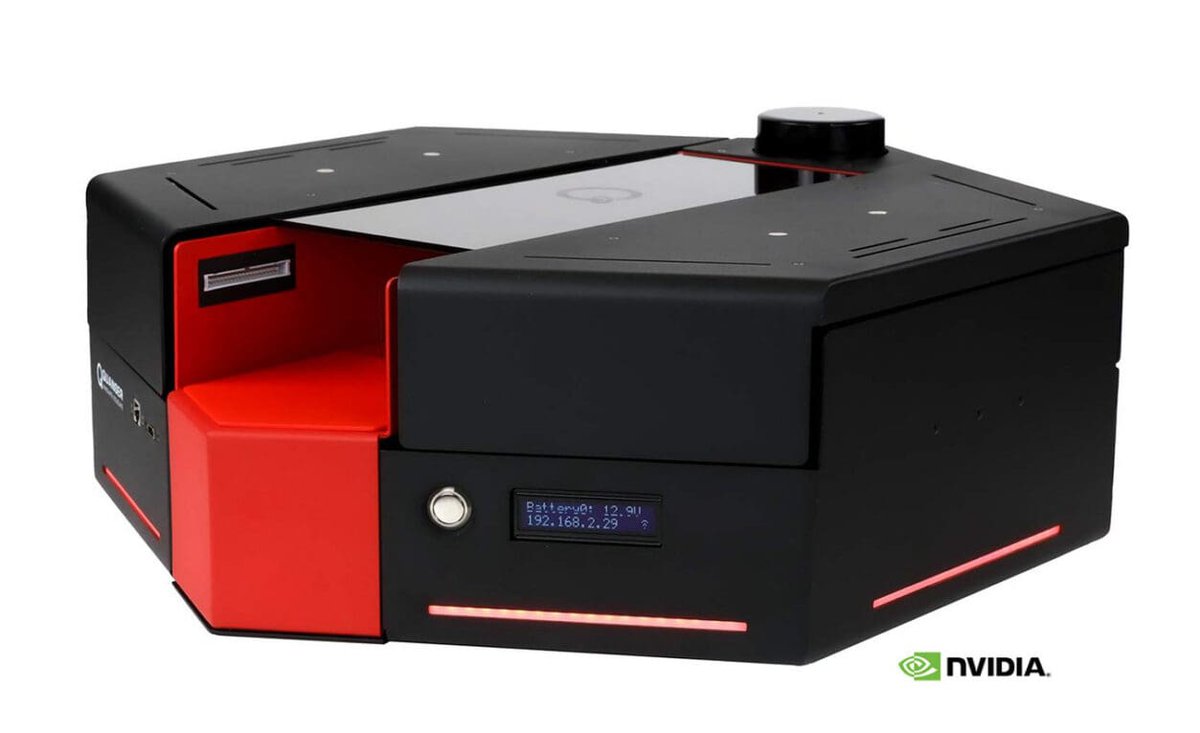
The Quanser QBot Platform is an innovative open-architecture autonomous ground robot, built on a differential drive mobile platform. This solution is ideal for teaching undergraduate and graduate mobile robotics as it is accompanied by comprehensive courseware and equipped with built-in sensors such as LiDAR, front-facing RealSense camera, downward-facing camera, gyroscope, and accelerometer, all powered by an onboard NVIDIA Jetson Orin Nano computer.
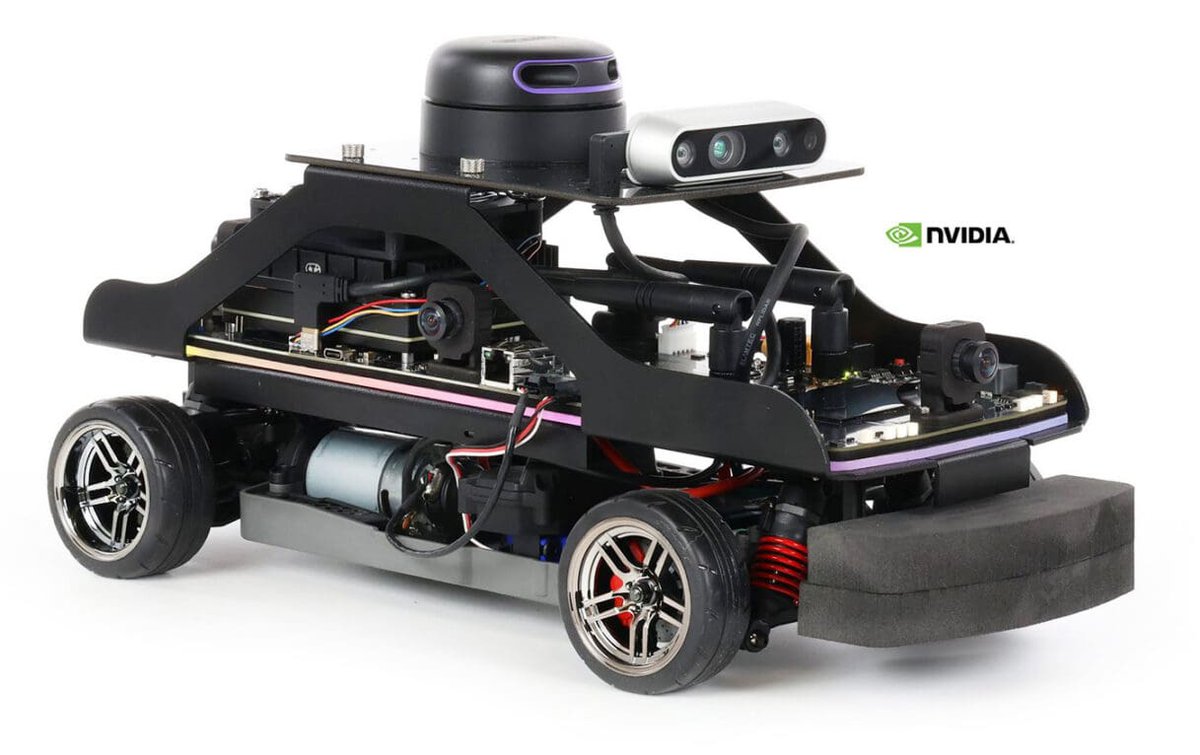
The QCar 2 is the feature vehicle of the Self-Driving Car Studio, an open-architecture, 1/10th scale vehicle designed for
academic self-driving initiatives. Driven by the powerful NVIDIA Orin AGX and equipped with a comprehensive suite of inertial, visual, and ranging sensors, it is designed to elevate your research, education, and outreach to the next level.
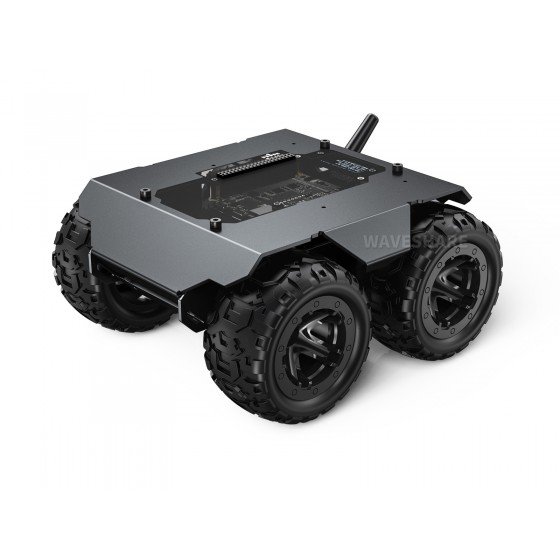
The WAVE ROVER is a full metal body 4WD mobile robot chassis, which features superb off-road crossing ability and shock-absorbing performance, open source all code for secondary development. It supports multiple host computers (Raspberry Pi, Jetson Nano, Jetson Orin Nano, etc), the host computer can communicate with the ESP32 slave computer through the serial port. Equipped with four N20 geared motors using a high-quality gearbox, which allows the mobile robot to drive at high speed with great power.
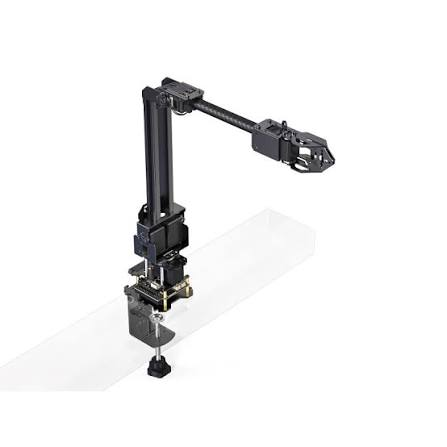
RoArm-M2 is a 4DOF smart robotic arm designed for innovative applications. Adopts lightweight structure design with a total weight of less than 900g and the effective payload of 0.5kg@0.5m, it can be flexibly mounted on various mobile platforms. Adopts a 360°omnidirectional base combined with three flexible joints to create a workspace with a 1-meter diameter. The joint direct-drive design enhances positioning precision and also improves structural reliability, with innovative dual-drive technology doubling the shoulder joint torque. Onboard ESP32 MCU main control module supports multiple wireless control modes, provides control interfaces and rich communication protocols for easily connecting to various devices.